Humanoids & robot training
Data collection, retargeting and RL for humanoid robots
Unitree, GR00T and LeRobot in production
Simulation and RL in Isaac Lab, scored with repeatable probes
Alexander Wiman · Independent consultant
I train humanoid robots and build the software that makes them, and your business, actually work.
Data collection, retargeting and training. I build the chain that gives a humanoid its first movements.
Web, apps, CRM, integrations and AI. One person, the whole chain.
I step in where the expertise is missing and deliver what has to work in production.
Data collection, retargeting and RL for humanoid robots
Unitree, GR00T and LeRobot in production
Simulation and RL in Isaac Lab, scored with repeatable probes
Fast, considered websites and web apps
Booking, CRM and customer portals that replace spreadsheets
React, TypeScript, Node and Postgres
iOS and Android from one codebase with React Native and Expo
Camera, sensors and ARKit when the app needs to see and measure
Published on the App Store, Google Play, and as a signed desktop app for macOS and Windows
Automation and AI integration in existing systems
ANPR, IoT and camera pipelines connected to the business
Integrations with Fortnox and other APIs
This is what a humanoid training pipeline looks like when I build it. Every step is something I have set up, debugged and run for real.
Motion capture with ARKit, teleoperation and simulated episodes. Known measurements and calibrated rigs.
Episodes normalised to LeRobot v3 and versioned on Hugging Face, with every file validated.
Human motion mapped to the robot's kinematics. Joint order and reach verified against the URDF.
Locomotion and manipulation environments in Isaac Lab. Reinforcement learning with domain randomization.
Fine-tuning NVIDIA GR00T N1.7 and LeRobot policies (ACT, diffusion, SmolVLA, pi0) on your own data, with checksummed, versioned artefacts.
A staged rollout pipeline: simulation validation, shadow and supervised stages, approval gates and rollback, with telemetry in Rerun.
A selection of what I have delivered, from a humanoid stack to a municipal app.
A platform for humanoid data collection and control: an iOS mocap app on ARKit, retargeting to a 31-DoF humanoid, LeRobot datasets, simulation and live visualisation. All the way from human motion to robot.
Booking site, customer management and automatic vehicle registration by camera. Check-in with no manual work.
Quotes, scheduling, spot checks, deviations and customer reports in one system. GPS zone time, INSTA 800 workflows and a Fortnox integration.
Expo app with collection schedules, reminders and a sorting guide for a Swedish municipality.
Apps & products. CareKeypr · Telve Sırları · Famio · WorkPark · Burhank · Verlo · MoodLoop · Stegkoll · Sunpilot UV
Robotics. Unitree · NVIDIA GR00T · Isaac Lab · Hugging Face · LeRobot · Reinforcement learning · MuJoCo · URDF / IK · ARKit · Teleoperation · Rerun · Python · PyTorch
Web & apps. TypeScript · React · React Native · Expo · Swift · Tauri · Rust · Node · Postgres · Supabase · Vite · Tailwind · Stripe
Systems & AI. LLM integration · Claude API · Automation · ANPR & IoT · Fortnox API · Docker · Railway / Vercel · CI/CD
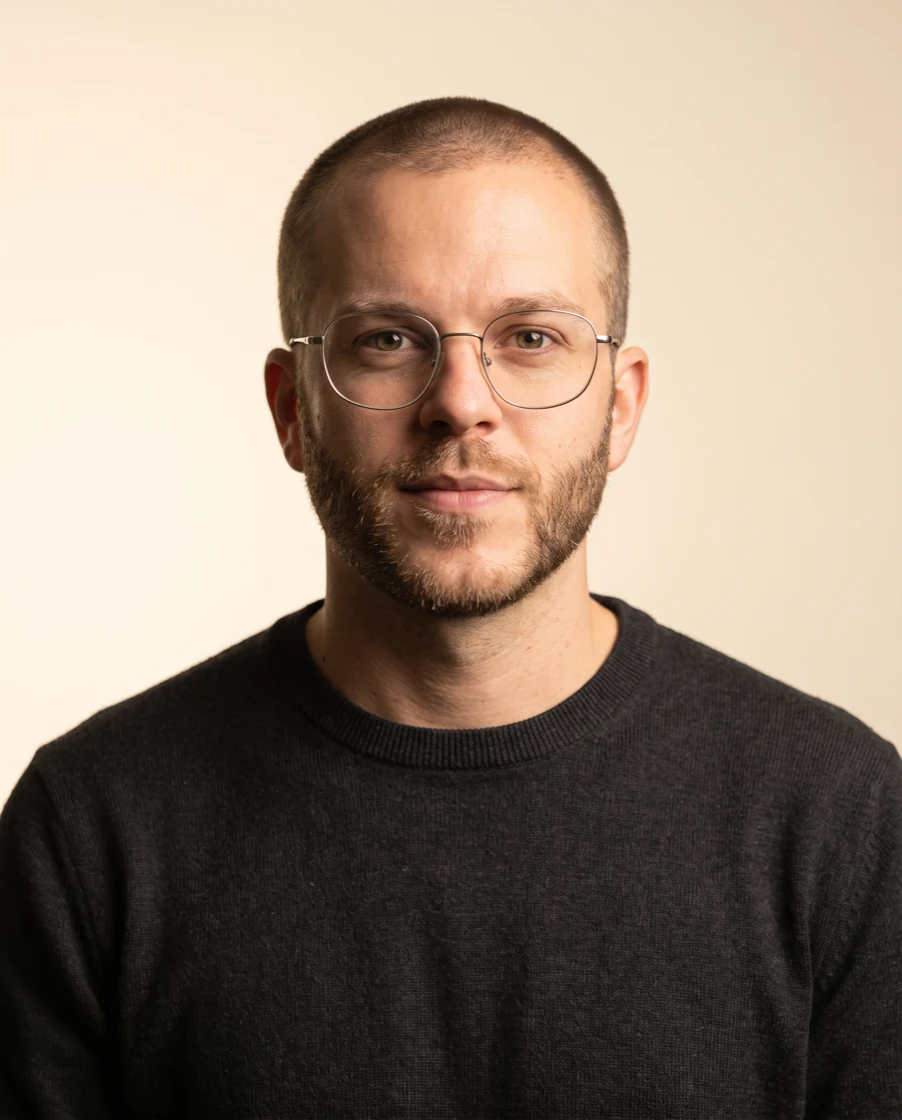
I have built digital products for more than ten years: SaaS platforms, mobile apps and systems for the public sector. In recent years my focus has been humanoid robots and how to teach them to work, from data collection to a policy in production.
What I offer is simple: one person who covers the whole chain, writes code that runs in production, and tells you what is realistic before the project starts.
Engagements. Hourly, retainer or fixed price per project.
Roles. Robotics engineer, tech lead, full-stack, app developer, advisor.
Location. Stockholm and remote. Travel across Europe.
Tell me briefly about the project. I usually reply within 24 hours.
[email protected] · Stockholm / remote · available for new engagements